Description
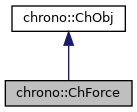
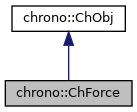
Forces are objects which must be attached to rigid bodies in order to apply force or torque to such body.
ChForce objects are able to represent either forces and torques, depending on a flag.
#include <ChForce.h>
Public Types | |
| enum | ForceType { FORCE, TORQUE } |
| Types of force application. | |
| enum | ReferenceFrame { BODY, WORLD } |
| Reference for position frame. | |
| enum | AlignmentFrame { BODY_DIR, WORLD_DIR } |
| Reference for alignment. | |
Public Member Functions | |
| ChForce () | |
| Construct a ChForce object. More... | |
| ChForce (const ChForce &other) | |
| virtual ChForce * | Clone () const override |
| "Virtual" copy constructor (covariant return type). | |
| ChBody * | GetBody () |
| Return the parent body (the force belongs to this rigid body) | |
| void | SetBody (ChBody *newRB) |
| Sets the parent body (the force belongs to this rigid body) | |
| void | SetMode (ForceType m_mode) |
| Sets the mode (force or torque) | |
| ForceType | GetMode () const |
| void | SetAlignment (AlignmentFrame m_align) |
| Sets the alignment method. More... | |
| AlignmentFrame | GetAlignment () const |
| void | SetFrame (ReferenceFrame ref_frame) |
| Sets the alignment method. More... | |
| ReferenceFrame | GetFrame () const |
| const ChVector3d & | GetApplicationPointAbs () const |
| Gets the application point, in absolute coordinates. | |
| const ChVector3d & | GetApplicationPointRel () const |
| Gets the application point, in rigid body coordinates. | |
| void | SetApplicationPointAbs (const ChVector3d &point_abs) |
| Sets the application point, in absolute coordinates. | |
| void | SetApplicationPointRel (const ChVector3d &point_rel) |
| Sets the application point, in rigid body coordinates. | |
| const ChVector3d & | GetDirAbs () const |
| Gets the force (or torque) direction, in absolute coordinates. | |
| const ChVector3d & | GetDirRel () const |
| Gets the force (or torque) direction, in rigid body coordinates. | |
| void | SetDirAbs (const ChVector3d &newdir_abs) |
| Sets the force (or torque) direction, in absolute coordinates. | |
| void | SetDirRel (const ChVector3d &newdir_rel) |
| Sets the force (or torque) direction, in rigid body coordinates. | |
| void | SetForceMagnitude (double newf) |
| Sets force (or torque) base magnitude. More... | |
| double | GetForceMagnitude () const |
| Gets force (or torque) base magnitude. More... | |
| void | SetMagnitudeModulation (std::shared_ptr< ChFunction > func) |
| Sets a function for time-modulation of the force (or torque) magnitude. | |
| std::shared_ptr< ChFunction > | GetMagnitudeModulation () const |
| void | SetForceModulationX (std::shared_ptr< ChFunction > func) |
| Sets a function for time-modulation of force (or torque), X component. | |
| std::shared_ptr< ChFunction > | GetForceModulationX () const |
| void | SetForceModulationY (std::shared_ptr< ChFunction > func) |
| Sets a function for time-modulation of force (or torque), Y component. | |
| std::shared_ptr< ChFunction > | GetForceModulationY () const |
| void | SetForceModulationZ (std::shared_ptr< ChFunction > func) |
| Sets a function for time-modulation of force (or torque), Z component. | |
| std::shared_ptr< ChFunction > | GetForceModulationZ () const |
| void | SetApplicationPointModulationX (std::shared_ptr< ChFunction > func) |
| Sets a function for time-modulation of application point position, X component. | |
| std::shared_ptr< ChFunction > | GetApplicationPointModulationX () const |
| void | SetApplicationPointModulationY (std::shared_ptr< ChFunction > func) |
| Sets a function for time-modulation of application point position, Y component. | |
| std::shared_ptr< ChFunction > | GetApplicationPointModulationY () const |
| void | SetApplicationPointModulationZ (std::shared_ptr< ChFunction > func) |
| Sets a function for time-modulation of application point position, Z component. | |
| std::shared_ptr< ChFunction > | GetApplicationPointModulationZ () const |
| const ChVector3d & | GetTotalForceAbs () const |
| Gets the total instant force (or torque) vector in absolute coordinates. More... | |
| const ChVector3d & | GetTotalForceRel () const |
| Gets the total instant force (or torque) vector in rigid body coordinates. More... | |
| void | GetBodyForceTorque (ChVector3d &body_force, ChVector3d &body_torque) const |
| Gets total force-torque applied to rigid body, as force vector (in absololute coords) and torque vector (in body coords). | |
| const ChVectorN< double, 7 > & | GetQf () const |
| Gets force-torque applied to rigid body, as lagrangian generalized force (7x1 matrix). | |
| void | UpdateState () |
| virtual void | Update (double time, UpdateFlags update_flags) override |
| Perform any updates necessary at the current phase during the solution process. More... | |
| virtual void | ArchiveOut (ChArchiveOut &archive_out) override |
| Method to allow serialization of transient data to archives. | |
| virtual void | ArchiveIn (ChArchiveIn &archive_in) override |
| Method to allow deserialization of transient data from archives. | |
 Public Member Functions inherited from chrono::ChObj | |
| ChObj (const ChObj &other) | |
| int | GetIdentifier () const |
| Get the unique integer identifier of this object. More... | |
| void | SetTag (int tag) |
| Set an object integer tag (default: -1). More... | |
| int | GetTag () const |
| Get the tag of this object. | |
| void | SetName (const std::string &myname) |
| Set the name of this object. | |
| const std::string & | GetName () const |
| Get the name of this object. | |
| double | GetChTime () const |
| Gets the simulation time of this object. | |
| void | SetChTime (double m_time) |
| Sets the simulation time of this object. | |
| void | AddVisualModel (std::shared_ptr< ChVisualModel > model) |
| Add an (optional) visualization model. More... | |
| std::shared_ptr< ChVisualModel > | GetVisualModel () const |
| Access the visualization model (if any). More... | |
| void | AddVisualShape (std::shared_ptr< ChVisualShape > shape, const ChFrame<> &frame=ChFrame<>()) |
| Add the specified visual shape to the visualization model. More... | |
| std::shared_ptr< ChVisualShape > | GetVisualShape (unsigned int i) const |
| Access the specified visualization shape in the visualization model (if any). More... | |
| virtual ChFrame | GetVisualModelFrame (unsigned int nclone=0) const |
| Get the reference frame (expressed in and relative to the absolute frame) of the visual model. More... | |
| virtual unsigned int | GetNumVisualModelClones () const |
| Return the number of clones of the visual model associated with this object. More... | |
| void | AddCamera (std::shared_ptr< ChCamera > camera) |
| Attach a camera to this object. More... | |
| std::vector< std::shared_ptr< ChCamera > > | GetCameras () const |
| Get the set of cameras attached to this object. | |
| void | UpdateVisualModel () |
| Utility function to update only the associated visual assets (if any). | |
| virtual std::string & | ArchiveContainerName () |
Additional Inherited Members | |
| Protected Member Functions inherited from chrono::ChObj | |
| int | GenerateUniqueIdentifier () |
| Protected Attributes inherited from chrono::ChObj | |
| double | ChTime |
| object simulation time | |
| std::string | m_name |
| object name | |
| int | m_identifier |
| object unique identifier | |
| int | m_tag |
| user-supplied tag | |
| std::shared_ptr< ChVisualModelInstance > | vis_model_instance |
| instantiated visualization model | |
| std::vector< std::shared_ptr< ChCamera > > | cameras |
| set of cameras | |
Constructor & Destructor Documentation
◆ ChForce()
| chrono::ChForce::ChForce | ( | ) |
Construct a ChForce object.
By default, it is initialized as FORCE mode, BODY frame, and BODY_DIR alignment.
Member Function Documentation
◆ GetForceMagnitude()
|
inline |
Gets force (or torque) base magnitude.
NB: this value gets modulated by related functions to provide total force.
◆ GetTotalForceAbs()
|
inline |
Gets the total instant force (or torque) vector in absolute coordinates.
This considers the effect of all applied modulations.
◆ GetTotalForceRel()
|
inline |
Gets the total instant force (or torque) vector in rigid body coordinates.
This considers the effect of all applied modulations.
◆ SetAlignment()
|
inline |
Sets the alignment method.
The force will rotate together with this reference.
◆ SetForceMagnitude()
| void chrono::ChForce::SetForceMagnitude | ( | double | newf | ) |
Sets force (or torque) base magnitude.
NB: this value gets modulated by related functions to provide total force.
◆ SetFrame()
| void chrono::ChForce::SetFrame | ( | ReferenceFrame | ref_frame | ) |
Sets the alignment method.
The force application point will follow this reference.
◆ Update()
|
overridevirtual |
Perform any updates necessary at the current phase during the solution process.
This function is called at least once per step to update auxiliary data, internal states, etc. The default implementation updates the item's time stamp and its visualization assets (if any are defined anf only if requested).
Reimplemented from chrono::ChObj.
The documentation for this class was generated from the following files:
- /builds/uwsbel/chrono/src/chrono/physics/ChForce.h
- /builds/uwsbel/chrono/src/chrono/physics/ChForce.cpp